
The need for parallel task processing and reliable hardware resource management makes the choice of an operating system a decisive choice in embedded system development. Modern real-time embedded systems control everything: automotive braking systems, medical monitors, industrial robots, smart IoT sensors, and much more.
In this guide, we will analyze the architecture of an RTOS in detail, discuss the main criteria for selecting a kernel, and outline how to effectively organize RTOS software development for projects of any complexity.
What Makes an RTOS Essential for Modern Embedded Systems?
Using a specialized operating system makes it possible to address a wide range of challenges regarding resource management and microcontroller response times. Below are the main concepts and characteristics that necessitate a shift to a real-time architecture.
Real-Time Operating System vs. General-Purpose Operating System
The primary distinction between a real-time operating system and general-purpose operating systems – like Windows, macOS, or standard Linux – lies in their predictability. GPOSs are designed to maximize average throughput and user convenience; if a process is delayed by 50 milliseconds due to a background update, the user will not notice.
In RTOS development, however, even a one-microsecond delay is unacceptable, as it could lead to a catastrophe. A standard OS offers no guarantees regarding event response times, whereas an embedded RTOS guarantees task execution within a strictly defined time interval.
Hard Real-Time, Firm Real-Time, and Soft Real-Time Requirements
Depending on the criticality of timing constraints, embedded RTOS systems fall into three categories:
- Hard real-time. Missing a deadline is equivalent to a fatal system failure; examples include airbag control systems, avionics, and medical defibrillators.
- Firm real-time. Infrequent missed deadlines do not destroy the system but render the task result useless; an example is a video stream in a commercial surveillance system.
- Soft real-time. Missing a deadline degrades system performance but does not cause a system failure; examples include user interfaces and reading data from climate sensors.
Deterministic Response, Scheduling, and Interrupt Latency
System reliability is ensured by a deterministic operating system, in which operation execution time is predictable and independent of current processor load. Main metrics here include real-time scheduling algorithms and interrupt latency (the time elapsed between the occurrence of a hardware interrupt and the execution of the first instruction of its handler). The lower and more stable the interrupt latency, the higher the device's determinism.
Where RTOS Application Development Is Commonly Used
Commercial and engineering practice shows that RTOS application development is in demand in sectors requiring precise timing and the concurrent execution of multiple tasks on microcontrollers:
- Automotive electronics (motor drivers, ADAS, infotainment);
- Industrial automation and robotics (PLCs, drives);
- Medical equipment (ventilators, infusion pumps);
- Communications and IoT (smart meters, trackers, gateways).
Core RTOS Architecture and Components Developers Should Evaluate
The foundation of any real-time system consists of interconnected kernel modules and synchronization services. Evaluating these components allows you to determine how effectively the OS handles hardware resource allocation.
RTOS Kernel and Task Management
The main part of any system is the RTOS kernel. It is the minimal software layer responsible for RTOS task management, CPU time allocation, and basic synchronization. This component defines how tasks are created, deleted, and transitioned between states such as ‘Ready’, ‘Running’, and ‘Blocked’.
Preemptive vs. Cooperative Multitasking
There are two main approaches to sharing processor time:
- Cooperative multitasking. A task executes until it voluntarily yields control to the scheduler; while the approach is simple, a single stalled task can block the entire system.
- Preemptive scheduling. The scheduler can interrupt the execution of a low-priority task at any time if a higher-priority task becomes ready; this is the standard for real-time systems.
Priority-Based Scheduling and Context Switching
Most systems employ task scheduling in RTOS based on absolute priorities. When a high-priority task is ready to run, a context switch occurs (saving the current task's registers to its stack and loading the new task's registers). The faster the kernel performs context switching, the higher the overall performance.
Inter-Task Communication: Queues, Semaphores, Mutexes, and Events
RTOS synchronization mechanisms are used for safe data exchange and coordination. Main primitives include:
- Queues. Transferring data streams or structures between tasks using a FIFO principle.
- Semaphores and mutexes. Semaphores are used for resource counting or event signaling, while mutexes ensure mutual exclusion when accessing shared resources.
- Event groups. Flags that allow a task to wait for the fulfillment of one or more conditions.
Memory Management and Resource Allocation
RTOS memory management in embedded systems has its own characteristics. Classic dynamic allocation pools are prohibited in hard real-time systems due to memory fragmentation and non-deterministic execution time. During embedded application development, engineers use static memory pools or fixed-size memory blocks.
Interrupt Handling and Real-Time Performance
Interrupt service routines must be kept as short as possible. In an RTOS architecture, heavy processing is offloaded from the ISR to a standard task using deferred interrupt handling mechanisms (such as sending a notification via a mutex or a queue).
Main Criteria for Choosing the Right RTOS for Embedded Development
Choosing the right platform prevents architectural deadlocks and minimizes financial risks during the production phase. Below are the system criteria you need to evaluate against the constraints of your target device.
Real-Time Performance and Deterministic Behavior
The first step in determining how to choose an RTOS is evaluating maximum context-switching times and interrupt latency under worst-case load scenarios.
MCU, MPU, and Hardware Architecture Compatibility
You must ensure the kernel supports your target controller family (ARM Cortex-M, RISC-V, ESP32, MIPS, etc.). A high-quality microcontroller RTOS comes with ready-made ports for specific architectures.
Memory Footprint and Resource Constraints
For low-power embedded systems, RAM and Flash capacity is severely limited. Kernel size can range from 2 KB (minimal FreeRTOS) to tens of kilobytes for community builds that include built-in network protocol stacks.
Scalability for Complex RTOS Application Development
For scalable projects, the architecture must allow for the easy addition of new modules without requiring a complete system rewrite, while maintaining a clean embedded software architecture.
Connectivity, Networking, and Communication Protocol Support
Modern projects often require support for RTOS communication protocols such as TCP/IP (LwIP), BLE, Wi-Fi, Thread, CANopen, and MQTT. The availability of proven stacks accelerates development.
Security Features and Secure Embedded Software Development
To protect connected devices, RTOS security mechanisms are essential – such as privilege separation support, task isolation, and secure key storage. These form the foundation for secure embedded systems.
Safety Certifications and Industry Compliance
When developing a safety-critical or automotive RTOS, the kernel must hold certifications of compliance with safety standards such as ISO 26262 (automotive), IEC 61508 (industrial), IEC 62304 (medical), and DO-177C (aviation).
Licensing, Commercial Support, and Total Cost of Ownership
The choice between MIT licenses and proprietary licenses is important because it will affect the level of legal risk and the costs of support in the long run.
Popular RTOS Options for Embedded Systems Compared
Here is a brief overview of stable, well-known operating systems that have earned the trust of engineers worldwide.
FreeRTOS for Microcontroller-Based Embedded Applications
If you need a lightweight MCU operating system, FreeRTOS is an excellent choice (it is currently supported by Amazon). FreeRTOS development is resource-efficient – requiring only 2-5 KB of Flash memory – and is therefore used in millions of diverse devices across the globe.
Zephyr RTOS for Connected and IoT Devices
This is a project under the Linux Foundation. Zephyr RTOS includes a vast array of built-in drivers and stacks for Bluetooth, Wi-Fi, and 802.15.4, and features a Kconfig/Devicetree configuration system. These properties make it an excellent choice for IoT RTOS applications.
ThreadX/Eclipse ThreadX for Resource-Constrained Systems
Formerly a commercial product, ThreadX RTOS is now an open-source project managed by the Eclipse Foundation. This OS holds extensive safety certifications and delivers top-tier performance.
VxWorks for Mission-Critical RTOS Development
This is a commercial OS from Wind River. Today, VxWorks RTOS is considered the standard solution for the aerospace, defense, and heavy industry sectors, as it provides developers with everything needed to ensure determinism and supports complex MPU/SMP systems.
QNX for Automotive and Safety-Critical Embedded Systems
QNX RTOS is a microkernel OS from BlackBerry that is most commonly found in automotive dashboards and autonomous systems. This can be attributed to its architecture, which isolates drivers and services from the kernel.
NuttX for POSIX-Compatible Embedded Application Development
NuttX RTOS provides a high level of compatibility with POSIX standards (IEEE 1003.1). This enables engineers to port C code from Linux to microcontrollers without major modifications.
Embedded Linux vs RTOS: When Each Approach Makes Sense
The embedded Linux vs RTOS comparison must consider resource consumption and the tasks assigned to the operating system. Specifically, Linux requires an MPU and at least 32 MB of RAM, though it boots up in seconds; however, it is not a hard real-time system out of the box. An embedded RTOS, conversely, runs on low-cost microcontrollers with mere kilobytes of RAM and starts up in milliseconds.
Regarding open-source RTOS options (such as FreeRTOS vs Zephyr), they are distributed under free licenses like MIT or Apache 2.0 but require independent certification. In contrast, commercial RTOS solutions like VxWorks or QNX come with pre-existing safety certifications, SLAs, and technical support.
RTOS Comparison by Technical Requirements
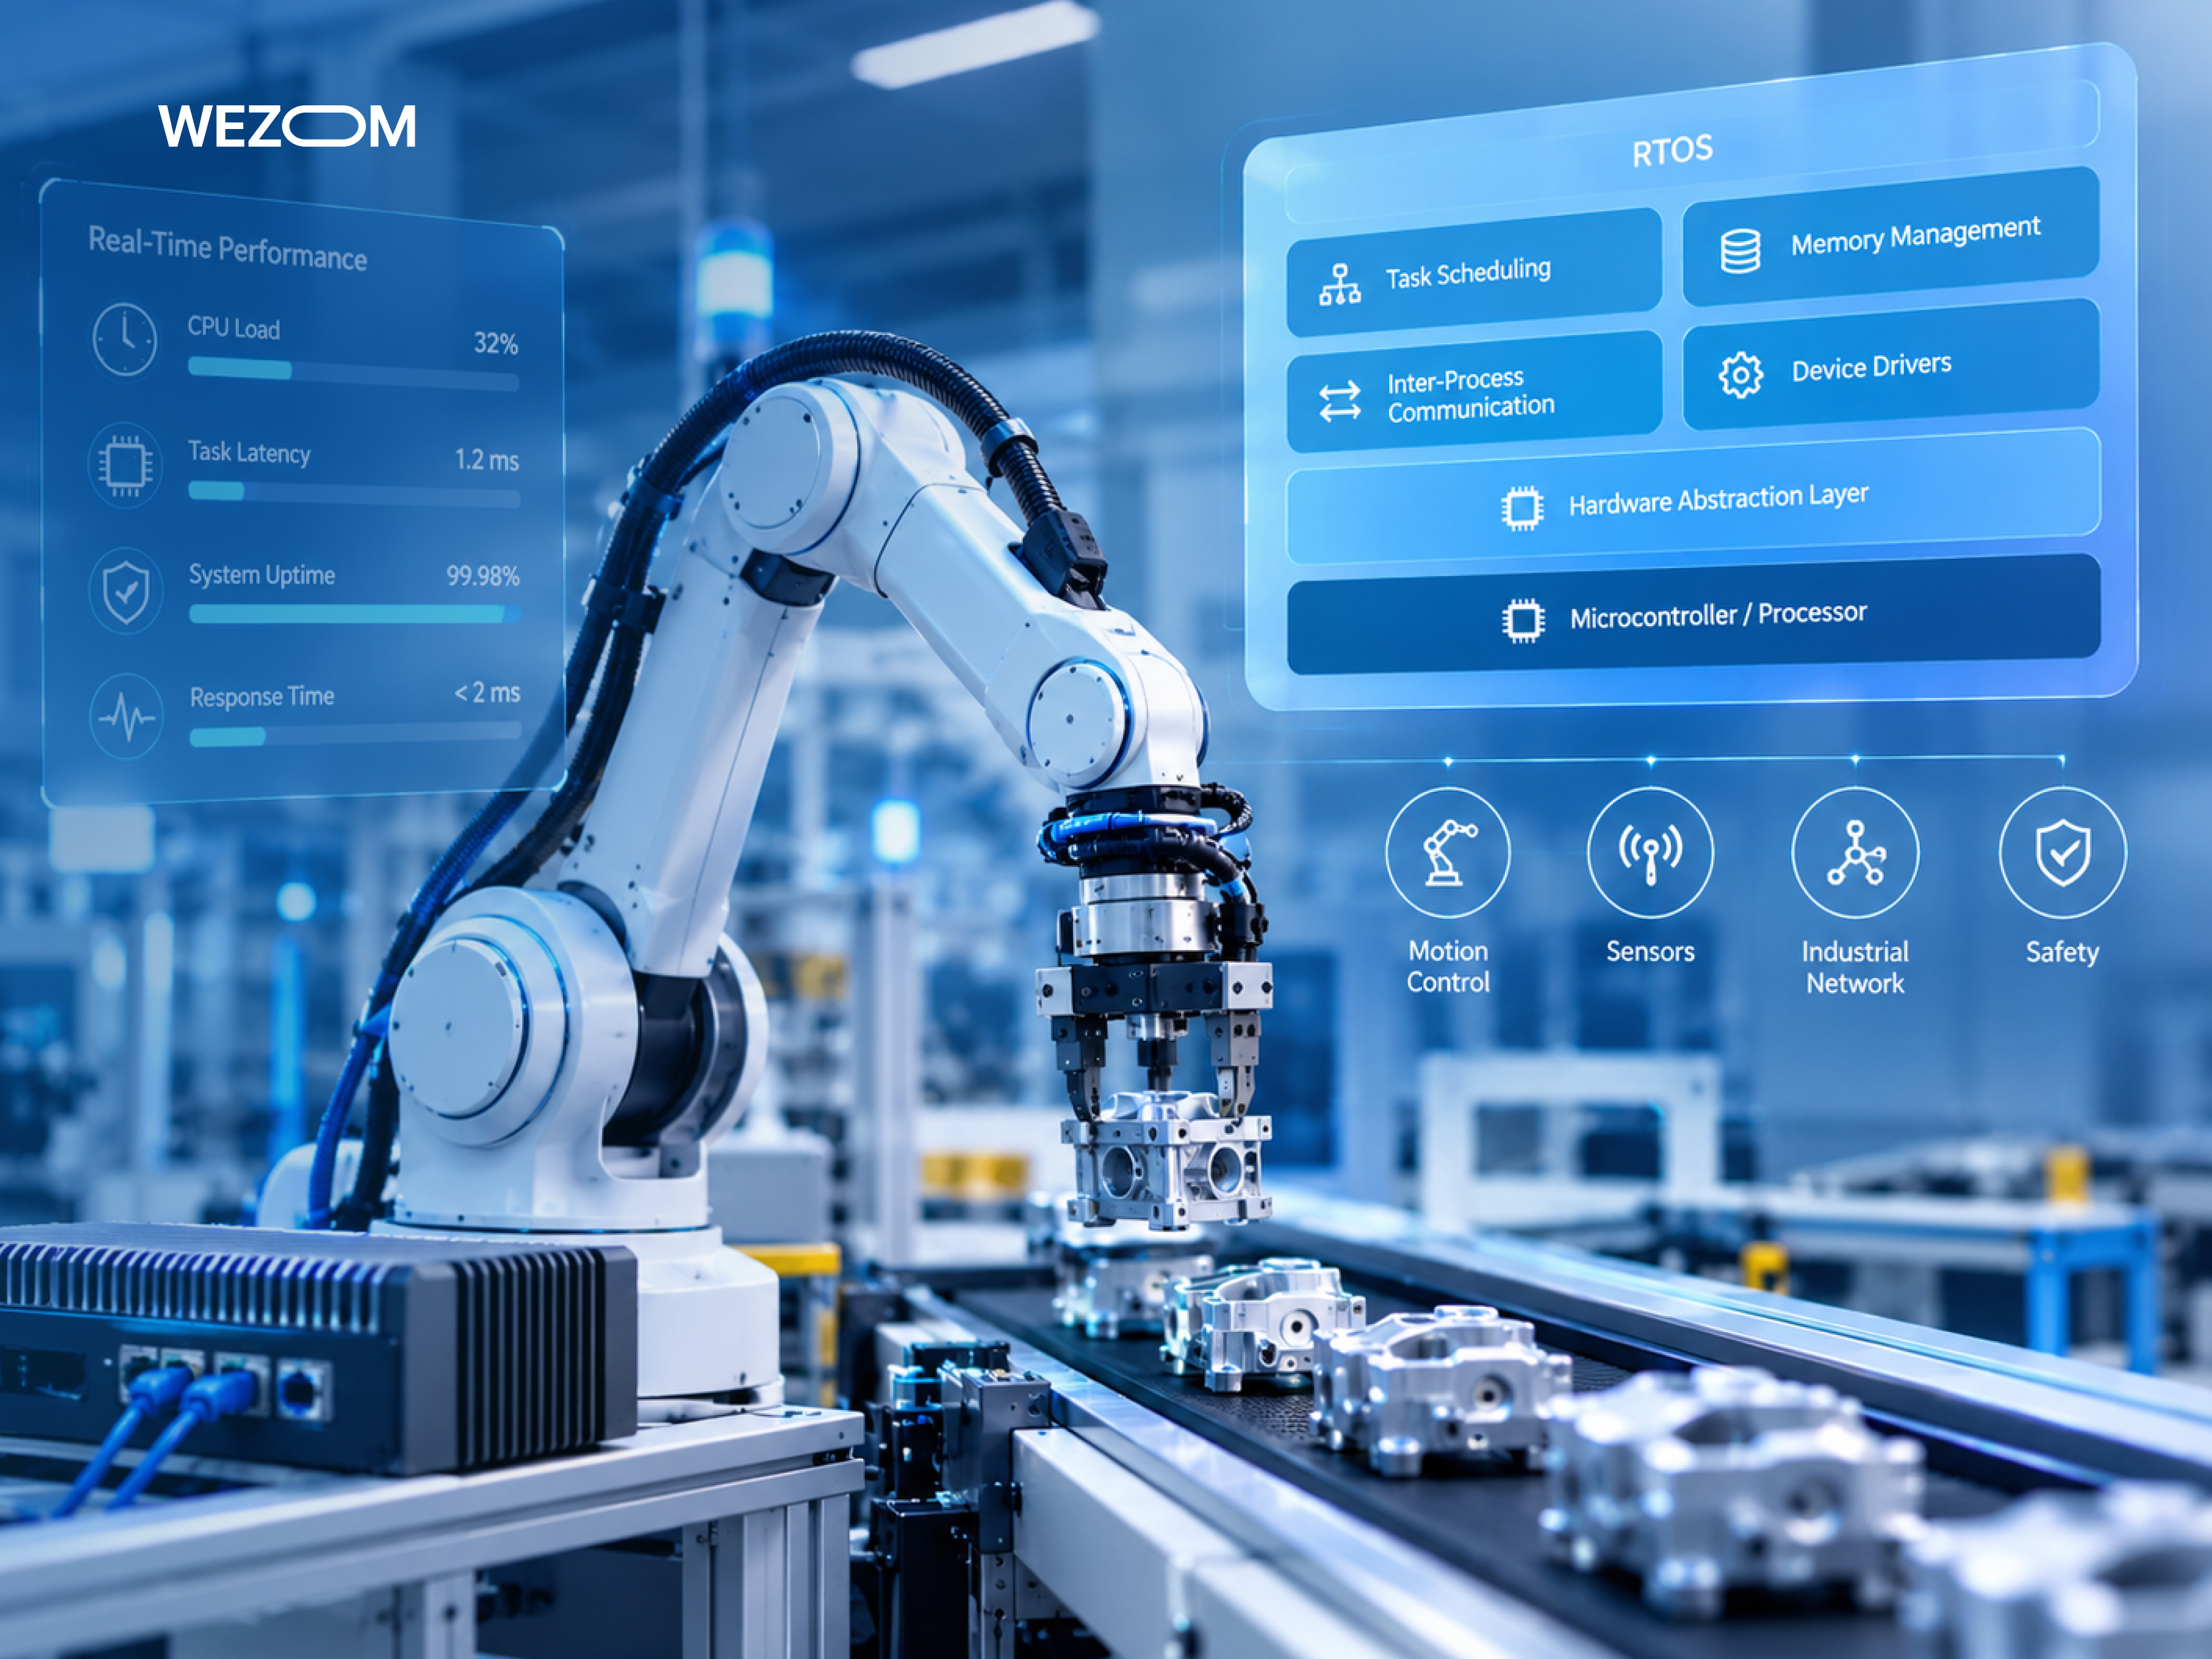
The project's technical parameters determine the type of operating system that is suitable. That is why we have decided to categorize operating systems below based on industry scenarios and tasks.
Best RTOS for Low-Power IoT Devices
Zephyr and FreeRTOS are considered the best RTOS for embedded systems requiring low energy consumption. They are optimized for microcontroller-based RTOS environments and feature built-in power management frameworks (such as Tickless Idle mode).
Best RTOS for Automotive Embedded Systems
QNX RTOS or commercial distributions based on SafeRTOS/AUTOSAR OS are considered the optimal choices here.
Best RTOS for Industrial Automation and Robotics
In this case, we recommend considering VxWorks RTOS or industrial RTOS solutions (it is important that they support EtherCAT and industrial bus systems).
Best RTOS for Medical and Safety-Critical Devices
For safety-critical RTOS tasks, it makes sense to choose either Eclipse ThreadX or SafeRTOS – both offer ready-made certified documentation packages.
Best RTOS for High-Performance Embedded Applications
It is worth considering the Embedded Linux vs. RTOS comparison here – specifically hybrid solutions (such as Linux + Xenomai) or NuttX RTOS (an OS based on powerful Cortex-R/A processors).
Open-Source RTOS vs Commercial RTOS Platforms
While open-source RTOSs offer flexibility and no upfront costs, commercial RTOSs come with manufacturer warranties and, typically, ready-made functional safety solutions.
RTOS Development Workflow: From Requirements to Deployment
Developing RTOS embedded systems requires a systematic, rigorously calibrated approach at every stage:
- Requirements analysis;
- BSP and kernel selection;
- Task architecture design;
- Driver and HAL development;
- Component integration;
- Testing;
- Deployment and OTA support.
Defining Timing, Latency, and Hardware Requirements
This is the initial stage of embedded systems development, during which maximum allowable response times, memory capacity, and power consumption requirements are defined.
Selecting the RTOS Kernel and Board Support Package
This stage involves selecting the core and the corresponding board support package for the chosen microcontroller.
Configuring Tasks, Priorities, and Scheduling Policies
You can now proceed to implement the task structure and assign priorities based on Rate Monotonic Scheduling methods.
Developing Device Drivers and Hardware Abstraction Layers
Developers can now proceed to create RTOS device drivers, using the hardware abstraction layer to isolate application code from the hardware.
Integrating Middleware, Communication Stacks, and File Systems
This step involves integrating additional components, including RTOS middleware, file systems, security stacks, and network protocols.
Testing Real-Time Behavior Under Production Workloads
This is the penultimate step, which involves verifying system stability and consists of conducting real-time performance testing at maximum interface load.
Firmware Deployment, Monitoring, and RTOS Maintenance
Finally, embedded firmware development is carried out, including over-the-air update delivery and the collection of performance metrics.
Performance Testing and Debugging in RTOS Development
Debugging systems that make use of multithreading are in many aspects different from debugging the code written in a sequential way due to timing issues of multithreaded systems. Efficient diagnostics will require specific tracing/profiling methods:
- Timing of task execution and interrupt latency measurement using specialized hardware timers and logic analyzers;
- RTOS tracing and execution analysis instruments (here, you can use visualization systems like SystemView and Percepio Tracealyzer to provide visual information on timing diagrams);
- Race condition detection and analysis of race conditions using various self-diagnostic features of the kernel;
- Stack overflow and memory leak detection by means of the built-in stack limit mechanism of the RTOS kernel;
- Hardware-in-loop testing for embedded RTOS apps and HIL testing systems for creation of physical signals and loads;
- Stress testing under worst-case execution scenarios.
Security Considerations for RTOS-Based Embedded Applications
Securing a connected device requires a comprehensive approach covering both the kernel and network communication layers. Implementing information security practices is a mandatory requirement for developing modern IoT equipment:
- Secure boot and firmware authentication. Ensure the microcontroller executes only authentic firmware signed by the manufacturer.
- Memory protection and task isolation. Using a hardware MPU will help you to prevent a task from accessing the memory of other threads or peripheral registers.
- Secure communication and cryptographic libraries. Here, integrating TLS/DTLS libraries and hardware-accelerated cryptographic functions is needed.
- OTA firmware updates and patch management. Implement a secure update mechanism with rollback capabilities in case of failure.
- Reducing the RTOS attack surface. Disable all unused services, protocols, and debug interfaces in production builds.
- Security requirements for connected IoT devices. Ensure compliance with standards such as ETSI EN 303 645 or NIST IR 8259 for smart devices.
Common RTOS Development Challenges and How to Avoid Them
Engineers designing real-time systems frequently encounter common hardware and software issues. Understanding the root causes allows for the proactive implementation of solutions.
Incorrect Task Priority Configuration
Priority inversion issues occur in low-priority tasks, eventually leading to starvation. The best solution is to make use of Rate Monotonic Analysis methods.
Excessive Memory Consumption on Resource-Constrained Hardware
Here, we mean insufficient RAM for task stacks. The solution is to carefully compute stack sizes with static code analysis tools and optimize the software accordingly.
Timing Jitter and Missed Real-Time Deadlines
The variability in response times is often induced by lengthy blocks from interrupts. To fix this issue, you should limit critical times.
Driver and Middleware Compatibility Issues
When the challenge lies in third-party libraries and RTOS multitasking model incompatibility, the best option is to work with reliable embedded software developers and use HAL abstractions.
Vendor Lock-In and RTOS Migration Complexity
If code is closely tied to a specific OS API, the best thing you can do is make OS API encasements with abstractions or use POSIX/CMSIS compatible instances.
Scaling a Prototype into a Production-Ready Embedded Product
To transit from development board prototype to mass production, carry out organized performance optimization of the RTOS in the early phases.
How to Choose an RTOS for Your Embedded Project Step by Step
The decision to select an OS should be based on a systematic project audit. The following step-by-step process helps minimize subjectivity when choosing a kernel:
- Define functional and real-time requirements. Determine whether you need hard, firm, or soft real-time capabilities.
- Identify hardware and memory constraints. Assess available resources: Flash and RAM capacity, as well as the presence of an MPU and FPU.
- Compare supported features and ecosystems. Compare available stacks (Net, USB, BLE, GUI) within the ecosystem.
- Review security and certification requirements. Clarify industry-specific certification requirements.
- Evaluate developer tools and technical support. Assess the usability of debuggers and tracers, as well as community activity.
- Build a proof of concept. Run a test project featuring multiple tasks and queues on the target hardware.
- Benchmark the RTOS under real-world conditions. Measure context switching times and interrupt latency.
- Estimate long-term RTOS development and maintenance costs. Calculate the total cost of ownership.
When Custom RTOS Development Services Make Sense
There are instances when the regular features of an OS do not fulfill distinct project needs. In these situations, seeking help from professionals can solve complicated engineering issues:
- Porting an RTOS to custom embedded hardware. If you use a proprietary processor or a niche architecture, a professional kernel port is required.
- Custom BSP and device driver development. Here, we mean developing high-performance, DMA-enabled drivers for specific sensors and peripherals as part of high-quality BSP development.
- Legacy firmware migration to an RTOS architecture. This covers transitioning legacy bare-metal code to a multitasking RTOS architecture without compromising reliability.
- RTOS performance optimization for production devices. In this context, conducting in-depth code audits, optimizing stack usage, and resolving elusive bugs before mass production are required.
- Integrating RTOS applications with cloud and IoT platforms. This includes connecting devices to AWS IoT, Azure IoT Hub, or private MQTT servers while adhering to all security standards.
FAQ
Can an embedded system work without an RTOS?
Yes, simple embedded systems function perfectly well using a classic bare-metal architecture without an operating system. However, as software complexity increases along with the addition of network stacks and requirements for concurrent task processing, the absence of an RTOS makes code maintenance and debugging significantly more difficult. In such cases, a real-time operating system becomes essential to ensure determinism and reliability.
How much RAM and flash memory does an RTOS typically require?
Minimalist kernels like FreeRTOS can require as little as 2-5 KB of Flash and less than 1 KB of RAM for their own operations. More advanced ecosystems, such as Zephyr RTOS or ThreadX, typically require 10-30 KB of Flash and 4-8 KB of RAM in their base configurations. The final memory footprint depends on the number of tasks created and the middleware included.
Can multiple RTOS platforms run on the same embedded device?
Yes, this is possible using a hardware hypervisor architecture or a SoC with multiple independent cores. In multi-core processors, one core can run under one RTOS (e.g., for hard real-time tasks), while another runs a different RTOS or even Embedded Linux for multimedia and UI functions. Implementing such a scheme on single-core systems is extremely difficult and usually lacks practical utility.
Is FreeRTOS suitable for commercial embedded products?
FreeRTOS is widely used in commercial devices worldwide and is distributed under the permissive MIT license. This license allows the kernel to be used in proprietary commercial firmware without royalty payments. For projects with stringent functional safety requirements, a certified commercial version – SafeRTOS is available.
How difficult is it to migrate an existing bare-metal application to an RTOS?
The complexity of migration is determined directly by the architecture of the firmware and the extent of its dependency on the hardware interface. The main issue is decomposing the loop from a monolithic one into several independent tasks and establishing a safe data transfer arrangement using queues and mutexes. If partitioning is done correctly from the hardware perspective, it takes several weeks up to several months.
Does using an RTOS increase power consumption?
The RTOS kernel itself imposes a minimal additional load on the processor due to context-switching overhead. However, most modern real-time operating systems support a “Tickless Idle” mode, which automatically puts the microcontroller into deep sleep when there are no active tasks. As a result, a well-designed RTOS application often consumes less power than a comparable bare-metal system.
What programming languages are commonly used for RTOS application development?
Due to the ability to directly access memory, utilize minimal memory resources, and achieve high performance, C RTOS programming language remains the standard choice. C++ becomes more popular, since it is capable of using the object-oriented approach while complying with the limits on memory allocation. Also, you should consider Rust, thanks to its built-in memory safety technologies.
How long does RTOS integration typically take for a new embedded product?
For an experienced engineer, basic kernel integration and BSP configuration on a ready-made development board usually take anywhere from a few days to a couple of weeks. The full real-time operating system development cycle – covering driver writing, network stack integration, RTOS debugging, and load testing – takes between 2 and 6 months on average. Timelines may extend if the project requires specialized functional safety certification.
